Abstract base class for a cartesian controller.
#include <ICartesianControl.h>
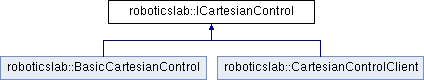
Classes | |
| struct | ControllerState |
| Controller state structure. More... | |
Public Types | |
| enum class | Vocabs { OK = yarp::os::createVocab32('o','k') , FAILED = yarp::os::createVocab32('f','a','i','l') , SET = yarp::os::createVocab32('s','e','t') , GET = yarp::os::createVocab32('g','e','t') , NOT_SET = yarp::os::createVocab32('n','s','e','t') } |
| General-purpose vocabs. More... | |
| enum class | Streaming { NOT_SET = yarp::os::createVocab32('n','s','e','t') , POSE = yarp::os::createVocab32('p','o','s','e') , TWIST = yarp::os::createVocab32('t','w','s','t') , WRENCH = yarp::os::createVocab32('w','r','n','c') } |
| Streaming vocabs. More... | |
| enum class | Mode { NONE = yarp::os::createVocab32('n','c','t','l') , MOVEJ = yarp::os::createVocab32('m','o','v','j') , MOVEL = yarp::os::createVocab32('m','o','v','l') , MOVEV = yarp::os::createVocab32('m','o','v','v') , GCMP = yarp::os::createVocab32('g','c','m','p') , FORCE = yarp::os::createVocab32('f','o','r','c') } |
| Controller mode vocabs. More... | |
| enum class | Actuator { NONE = yarp::os::createVocab32('a','c','n') , CLOSE = yarp::os::createVocab32('a','c','c','g') , OPEN = yarp::os::createVocab32('a','c','o','g') , STOP = yarp::os::createVocab32('a','c','s','g') , GENERIC = yarp::os::createVocab32('a','c','g') } |
| Actuator control vocabs. More... | |
| enum class | Config { GAIN = yarp::os::createVocab32('c','p','c','g') , TRAJ_DURATION = yarp::os::createVocab32('c','p','t','d') , TRAJ_REF_SPD = yarp::os::createVocab32('c','p','t','s') , TRAJ_REF_ACC = yarp::os::createVocab32('c','p','t','a') , CMC_PERIOD = yarp::os::createVocab32('c','p','c','p') , FRAME = yarp::os::createVocab32('c','p','f') , STREAMING_CMD = yarp::os::createVocab32('c','p','s','c') } |
| Controller configuration vocabs. More... | |
Public Member Functions | |
| virtual | ~ICartesianControl ()=default |
| Destructor. | |
| virtual bool | stat (std::vector< double > &x, int *state=nullptr, double *timestamp=nullptr) |
| virtual bool | inv (const std::vector< double > &xd, std::vector< double > &q) |
| virtual bool | movj (const std::vector< double > &xd) |
| virtual bool | relj (const std::vector< double > &xd) |
| virtual bool | movl (const std::vector< double > &xd) |
| virtual bool | movv (const std::vector< double > &xdotd) |
| virtual bool | gcmp () |
| virtual bool | forc (const std::vector< double > &fd) |
| virtual bool | wait (double timeout=0.0) |
| virtual bool | tool (const std::vector< double > &x) |
| virtual bool | act (int command) |
| virtual bool | setParameter (int vocab, double value) |
| virtual bool | getParameter (int vocab, double *value) |
| virtual bool | setParameters (const std::map< int, double > ¶ms) |
| virtual bool | getParameters (std::map< int, double > ¶ms) |
RPC commands | |
| virtual yarp::dev::ReturnValue | getState (ControllerState &state)=0 |
| Current state and position. | |
| virtual yarp::dev::ReturnValue | solvePose (const std::vector< double > &xd, std::vector< double > &q)=0 |
| Inverse kinematics. | |
| virtual yarp::dev::ReturnValue | moveJoint (const std::vector< double > &xd)=0 |
| Move in joint space. | |
| virtual yarp::dev::ReturnValue | moveLinear (const std::vector< double > &xd)=0 |
| Linear move to target position. | |
| virtual yarp::dev::ReturnValue | moveVelocity (const std::vector< double > &xdotd)=0 |
| Linear move with given velocity. | |
| virtual yarp::dev::ReturnValue | gravityCompensation ()=0 |
| Gravity compensation. | |
| virtual yarp::dev::ReturnValue | forceControl (const std::vector< double > &fd)=0 |
| Force control. | |
| virtual yarp::dev::ReturnValue | stopControl ()=0 |
| Stop control. | |
| virtual yarp::dev::ReturnValue | changeTool (const std::vector< double > &x)=0 |
| Change tool. | |
| virtual yarp::dev::ReturnValue | actuateTool (Actuator command)=0 |
| Actuate tool. | |
Streaming commands | |
| virtual void | pose (const std::vector< double > &x)=0 |
| Achieve pose. | |
| virtual void | twist (const std::vector< double > &xdot)=0 |
| Instantaneous velocity steps. | |
| virtual void | wrench (const std::vector< double > &w)=0 |
| Exert force. | |
Configuration accessors | |
|
Configuration setters and getters with success/failure response. | |
| using | config_value_t = std::variant< double, yarp::conf::vocab32_t > |
| using | config_map_t = std::map< Config, config_value_t > |
| virtual yarp::dev::ReturnValue | setParameter (Config vocab, config_value_t value)=0 |
| Set a configuration parameter. | |
| virtual yarp::dev::ReturnValue | getParameter (Config vocab, config_value_t &value)=0 |
| Retrieve a configuration parameter. | |
| virtual yarp::dev::ReturnValue | setParameters (const config_map_t ¶ms)=0 |
| Set multiple configuration parameters. | |
| virtual yarp::dev::ReturnValue | getParameters (config_map_t ¶ms)=0 |
| Retrieve multiple configuration parameters. | |
Member Enumeration Documentation
◆ Actuator
|
strong |
◆ Config
|
strong |
Used by configuration accessors.
◆ Mode
|
strong |
Used by ICartesianControl::getState to reflect current control mode.
| Enumerator | |
|---|---|
| NONE | Not controlling. |
| MOVEJ | Executing MOVEJ command. |
| MOVEL | Executing MOVEL command. |
| MOVEV | Executing MOVEV command. |
| GCMP | Executing GCMP command. |
| FORCE | Executing FORCE command. |
◆ Streaming
|
strong |
◆ Vocabs
|
strong |
Member Function Documentation
◆ actuateTool()
|
pure virtual |
Send control command to actuate the robot's tool, if available.
- Parameters
-
command One of the available ICartesianControl::Actuator vocabs.
- Returns
- true on success, false otherwise
Implemented in BasicCartesianControl, CartesianControlClient, and CartesianControlClientROS2.
◆ changeTool()
|
pure virtual |
Unload current tool if any and append new tool frame to the kinematic chain.
- Parameters
-
x 6-element vector describing new tool tip with regard to current end-effector frame in cartesian space; first three elements denote translation (meters), last three denote rotation in scaled axis-angle representation (radians).
- Returns
- true on success, false otherwise
Implemented in BasicCartesianControl, CartesianControlClient, and CartesianControlClientROS2.
◆ forceControl()
|
pure virtual |
Apply desired forces in task space.
- Parameters
-
fd 6-element vector describing desired force exerted by the TCP in cartesian space; first three elements denote linear force (Newton), last three denote torque (Newton*meters).
- Returns
- true on success, false otherwise
Implemented in BasicCartesianControl, CartesianControlClient, and CartesianControlClientROS2.
◆ getParameter()
|
pure virtual |
Ask the controller to retrieve a parameter of 'double' or 'vocab32_t' type.
- Parameters
-
vocab YARP-encoded vocab (parameter key). value Parameter value encoded as a double or vocab32_t.
- Returns
- true on success, false otherwise
Implemented in BasicCartesianControl, CartesianControlClient, and CartesianControlClientROS2.
◆ getParameters()
|
pure virtual |
Ask the controller to retrieve all available parameters at once.
- Parameters
-
params Dictionary of YARP-encoded vocabs as keys and their values encoded as double or vocab32_t.
- Returns
- true on success, false otherwise
Implemented in BasicCartesianControl, CartesianControlClient, and CartesianControlClientROS2.
◆ getState()
|
pure virtual |
Inform on control state, get robot position and perform forward kinematics.
- Parameters
-
state Controller state data.
- Returns
- true on success, false otherwise
Implemented in BasicCartesianControl, CartesianControlClient, and CartesianControlClientROS2.
◆ gravityCompensation()
|
pure virtual |
Enable gravity compensation.
- Returns
- true on success, false otherwise
Implemented in BasicCartesianControl, CartesianControlClient, and CartesianControlClientROS2.
◆ moveJoint()
|
pure virtual |
Perform inverse kinematics and move to desired position in joint space using absolute coordinates.
- Parameters
-
xd 6-element vector describing desired position in cartesian space; first three elements denote translation (meters), last three denote rotation in scaled axis-angle representation (radians).
- Returns
- true on success, false otherwise
Implemented in BasicCartesianControl, CartesianControlClient, and CartesianControlClientROS2.
◆ moveLinear()
|
pure virtual |
Move to end position along a line trajectory.
- Parameters
-
xd 6-element vector describing desired position in cartesian space; first three elements denote translation (meters), last three denote rotation in scaled axis-angle representation (radians).
- Returns
- true on success, false otherwise
Implemented in BasicCartesianControl, CartesianControlClient, and CartesianControlClientROS2.
◆ moveVelocity()
|
pure virtual |
Move along a line with constant velocity.
- Parameters
-
xdotd 6-element vector describing desired velocity in cartesian space; first three elements denote translational velocity (meters/second), last three denote angular velocity (radians/second).
- Returns
- true on success, false otherwise
Implemented in BasicCartesianControl, CartesianControlClient, and CartesianControlClientROS2.
◆ pose()
|
pure virtual |
Move to desired position instantaneously, no further intermediate calculations are expected other than computing the inverse kinematics.
- Parameters
-
x 6-element vector describing desired instantaneous pose in cartesian space; first three elements denote translation (meters), last three denote rotation in scaled axis-angle representation (radians).
Implemented in BasicCartesianControl, CartesianControlClient, and CartesianControlClientROS2.
◆ setParameter()
|
pure virtual |
Ask the controller to store or update a parameter of 'double' type.
- Parameters
-
vocab YARP-encoded vocab (parameter key). value Parameter value encoded as a double.
- Returns
- true on success, false otherwise
Implemented in BasicCartesianControl, CartesianControlClient, and CartesianControlClientROS2.
◆ setParameters()
|
pure virtual |
Ask the controller to store or update multiple parameters at once.
- Parameters
-
params Dictionary of YARP-encoded vocabs as keys and their values.
- Returns
- true on success, false otherwise
Implemented in BasicCartesianControl, CartesianControlClient, and CartesianControlClientROS2.
◆ solvePose()
|
pure virtual |
Perform inverse kinematics (using robot position as initial guess), but do not move.
- Parameters
-
xd 6-element vector describing desired position in cartesian space; first three elements denote translation (meters), last three denote rotation in scaled axis-angle representation (radians). q Vector describing current position in joint space (meters or degrees).
- Returns
- true on success, false otherwise
Implemented in BasicCartesianControl, CartesianControlClient, and CartesianControlClientROS2.
◆ stopControl()
|
pure virtual |
Halt current control loop if any and cease movement.
- Returns
- true on success, false otherwise
Implemented in BasicCartesianControl, CartesianControlClient, and CartesianControlClientROS2.
◆ twist()
|
pure virtual |
Move in instantaneous velocity increments.
- Parameters
-
xdot 6-element vector describing velocity increments in cartesian space; first three elements denote translational velocity (meters/second), last three denote angular velocity (radians/second).
Implemented in BasicCartesianControl, CartesianControlClient, and CartesianControlClientROS2.
◆ wrench()
|
pure virtual |
Make the TCP exert the desired force instantaneously.
- Parameters
-
w 6-element vector describing desired force exerted by the TCP in cartesian space; first three elements denote linear force (Newton), last three denote torque (Newton*meters).
Implemented in BasicCartesianControl, CartesianControlClient, and CartesianControlClientROS2.
The documentation for this class was generated from the following file:
- libraries/YarpPlugins/ICartesianControl.h
