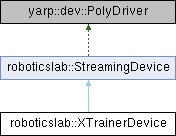
Represents an XTrainer-compatible device.
#include <XTrainerDevice.hpp>
|
|
| XTrainerDevice (yarp::os::Searchable &config) |
| |
| bool | acquireInterfaces () override |
| | Acquires plugin interfaces.
|
| |
| bool | initialize (const ICartesianControl::config_map_t ¶ms) override |
| | Perform any custom initialization needed. This method is called after the successful creation of the device and once all interface handles are acquired.
|
| |
| bool | acquireData () override |
| | Acquires data from remote device.
|
| |
| bool | transformData (double scaling) override |
| | Performs required operations on stored data.
|
| |
| ICartesianControl::Actuator | getActuatorState () override |
| | If actuator command data is available, return its current state.
|
| |
| void | sendMovementCommand (double timestamp) override |
| | Sends movement command to the cartesian controller.
|
| |
| | StreamingDevice (yarp::os::Searchable &config) |
| | Constructor.
|
| |
|
virtual | ~StreamingDevice () |
| | Destructor.
|
| |
| virtual bool | hasValidMovementData () const |
| | Checks whether the device may forward acquired and processed data to the controller.
|
| |
| virtual void | stopMotion () |
| | Sends a movement command that would stop motion.
|
| |
| void | setCartesianControllerHandle (ICartesianControl *iCartesianControl) |
| | Stores handle to an ICartesianControl instance.
|
| |
|
|
yarp::dev::IJoypadController * | iJoypadController {nullptr} |
| |
|
ICartesianSolver * | iCartesianSolver {nullptr} |
| |
|
yarp::dev::PolyDriver | solverDevice |
| |
|
std::string | kinematics |
| |
|
std::vector< double > | initialTcpOffset |
| |
|
std::vector< double > | initialDeviceOffset |
| |
|
KDL::Frame | H_base_device |
| |
|
KDL::Frame | H_ee_device |
| |
|
KDL::Frame | H_device_ee |
| |
|
bool | buttonClose {false} |
| |
|
bool | buttonOpen {false} |
| |
◆ acquireData()
| bool XTrainerDevice::acquireData |
( |
| ) |
|
|
overridevirtual |
◆ acquireInterfaces()
| bool XTrainerDevice::acquireInterfaces |
( |
| ) |
|
|
overridevirtual |
◆ getActuatorState()
◆ initialize()
| bool XTrainerDevice::initialize |
( |
const ICartesianControl::config_map_t & |
params | ) |
|
|
overridevirtual |
- Parameters
-
| params | Configuration parameters for the cartesian controller. |
- Returns
- true on success, false otherwise
Reimplemented from roboticslab::StreamingDevice.
◆ sendMovementCommand()
| void XTrainerDevice::sendMovementCommand |
( |
double |
timestamp | ) |
|
|
overridevirtual |
◆ transformData()
| bool XTrainerDevice::transformData |
( |
double |
scaling | ) |
|
|
overridevirtual |
- Parameters
-
| scaling | Scaling factor applied to each data value. |
- Returns
- true on success, false otherwise
Reimplemented from roboticslab::StreamingDevice.
The documentation for this class was generated from the following files:
- programs/streamingDeviceController/XTrainerDevice.hpp
- programs/streamingDeviceController/XTrainerDevice.cpp
 Public Member Functions inherited from roboticslab::StreamingDevice
